tools.nlinv#
- bartorch.tools.nlinv()#
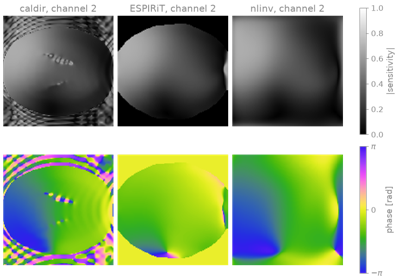
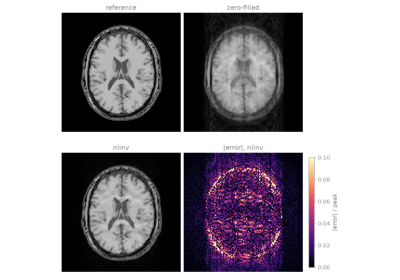
Nonlinear inversion: the image and the sensitivities together.
- Parameters:
kspace (torch.Tensor) – Under-sampled k-space, C order.
maxiter (int, default=None) – Gauss-Newton steps (
-i).maps (int, default=None) – How many sets of sensitivities to estimate (
-m).traj (tensor, default=None) – Non-Cartesian trajectory (
-t).pattern (tensor, default=None) – Sampling pattern (
-p).basis (tensor, default=None) – Subspace basis (
-B).initial (tensor, default=None) – Warm start (
-I).alpha (float, default=None) – The
aof the Sobolev coil weighting(1 + a |k|^2)^(-b/2)(-a), not the first step’s regularization weight – that isnlinv --alpha, reachable through**extra.real (bool, default=False) – Constrain the image to be real (
-c).normalize (bool, default=True) – Divide the image by the root sum of squares of the sensitivities, as
nlinvdoes unless told not to. BART spells this the other way round, as-Nfor “do not normalize”.return_sensitivities (bool, default=False) – Also return the sensitivities, which BART writes as a second array.
**extra – Further BART
nlinvoptions, by name.s, the axes the sensitivities are constant along, takes axes ofkspace.
- Returns:
The image, and the sensitivities when asked for.
- Return type:
torch.Tensor or tuple of torch.Tensor