

Note
Go to the end to download the full example code.
Rigid head motion from navigators#

Head motion during a scan changes the position of the anatomy between the readouts that encode it, and the image acquires blurring and ghosting. Prospective correction updates the imaging field of view with the measured head pose before each readout; it requires a measurement of the rigid pose with six degrees of freedom, repeated during the scan. A navigator is a short, low-resolution acquisition interleaved with the imaging readouts, and its registration against the first navigator of the scan measures how the head has moved since [1].
This example measures the rigid pose of a BrainWeb head from three orthogonal radial navigator planes, compares the navigator after motion and after the measured pose is applied with the reference navigator, and tracks a nodding and drifting head over a 12 s scan with a constant-velocity extended Kalman filter, as in PROMO [2], which tracks the head with three orthogonal spiral navigators.
Learning objectives
Relate each 2D navigator plane to the three degrees of freedom it measures, and the rigid pose to the nine measurements of three orthogonal planes.
Reconstruct radial navigator planes with
reconstruct_navigator()and measure the pose withNavigatorMotionTracker.Assess a measured pose by the residual between the navigator and the navigator of the head moved by that pose.
Set the filter’s process and measurement noise against the precision of the navigator and the dynamics of the motion.
import numpy as np
import torch
from brainweb_dl import get_mri
from scipy import ndimage
from scipy.spatial.transform import Rotation

import bartorch
import bartorch.tools as bt
The head#
A BrainWeb T1-weighted volume [3], downsampled to 2 mm isotropic and padded to \(112^3\). Array axis 0 runs inferior to superior (S/I), axis 1 posterior to anterior (A/P) and axis 2 left to right (L/R). Poses are stated in that frame: a rotation vector in radians about the centre of the volume, printed in degrees, and a translation in millimetres.
VOXEL_MM = 2.0


def move(rotvec, translation_mm):
    """The volume after a rigid motion about its centre."""
    rotation = Rotation.from_rotvec(rotvec).as_matrix()
    shift = np.asarray(translation_mm) / VOXEL_MM
    return ndimage.affine_transform(
        volume, rotation.T, offset=centre - rotation.T @ (centre + shift), order=1
    )
The navigator#
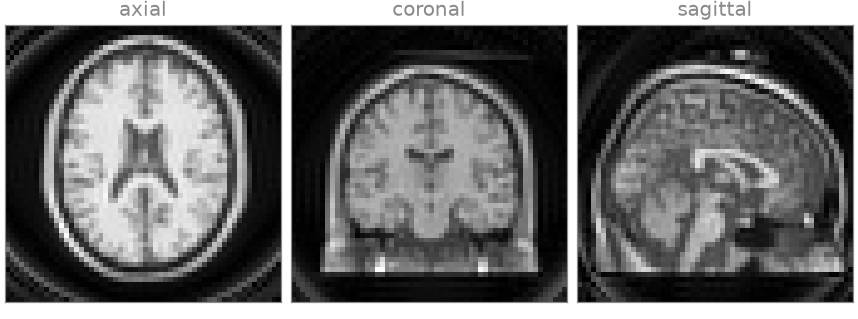
Each navigator is three central planes, axial, coronal and sagittal, each
acquired along 96 golden-angle radial spokes of 56 samples. The trajectory
is in grid units of a \(56^2\) matrix, so the spokes reach half the
imaging resolution and each plane is reconstructed at 4 mm over the full
field of view. reconstruct_navigator() grids a
plane by the density-compensated adjoint NUFFT, with weights from
bartorch.estimate_density().
AXES states, for each plane, the direction in the volume of its image’s
rows and columns; it is what relates each plane’s in-plane measurement to
the 3D pose.
NAV, SPOKES = 56, 96
golden = np.pi * (3 - np.sqrt(5))
angle = np.arange(SPOKES)[:, None] * golden
radius = np.arange(NAV) - NAV / 2
trajectory = torch.tensor(
    np.stack([np.cos(angle) * radius, np.sin(angle) * radius], axis=-1).reshape(-1, 2),
    dtype=torch.float32,
)
density = bartorch.estimate_density(trajectory, (NAV, NAV))

AXES = [
    ((0, 1, 0), (0, 0, 1)),  # axial: rows posterior-anterior, columns left-right
    ((1, 0, 0), (0, 0, 1)),  # coronal: rows inferior-superior, columns left-right
    ((1, 0, 0), (0, 1, 0)),  # sagittal: rows inferior-superior, columns posterior-anterior
]
SPACING_MM = VOXEL_MM * SIZE / NAV


def navigator(head, noise=0.0, generator=None):
    """The three navigator planes of ``head``, with complex Gaussian k-space noise."""
    middle = SIZE // 2
    planes = []
    for plane in (head[middle], head[:, middle], head[:, :, middle]):
        samples = bartorch.nufft(
            torch.tensor(plane, dtype=torch.complex64),
            torch.nn.functional.pad(trajectory, (0, 1))[None],
        ).reshape(1, -1)
        if noise:
            samples = samples + noise * torch.randn(
                samples.shape, dtype=torch.complex64, generator=generator
            )
        planes.append(
            bt.reconstruct_navigator(samples, trajectory[None], (NAV, NAV), density=density)[0]
        )
    return planes


reference = navigator(volume)
One pose#
NavigatorMotionTracker takes the first
navigator it is given as the reference and returns the pose of every later
one relative to it. Each plane is registered in 2D by
RigidRegistration; the pose is the
least-squares solution over the three planes.
rotvec = np.array([0.02, -0.03, 0.05])  # rad
translation = np.array([3.0, -2.0, 4.0])  # mm

tracker = bt.NavigatorMotionTracker(measurement_noise=1e-3)
tracker.track(reference, AXES, spacing=SPACING_MM)
moved = navigator(move(rotvec, translation))
pose = tracker.track(moved, AXES, spacing=SPACING_MM)

measured_rotvec = Rotation.from_matrix(np.asarray(pose.matrix)[:3, :3]).as_rotvec()
measured_translation = np.asarray(pose.translation)
NAMES = ("S/I", "A/P", "L/R")
print(f"{'':>14} {'truth':>7} {'measured':>9}")
for axis, name in enumerate(NAMES):
    print(
        f"rotation {name:>5} {np.degrees(rotvec[axis]):6.2f}° "
        f"{np.degrees(measured_rotvec[axis]):8.2f}°"
    )
for axis, name in enumerate(NAMES):
    print(f"shift    {name:>5} {translation[axis]:5.1f} mm {measured_translation[axis]:6.2f} mm")
                 truth  measured
rotation   S/I   1.15°     1.40°
rotation   A/P  -1.72°    -1.45°
rotation   L/R   2.86°     2.51°
shift      S/I   3.0 mm   3.37 mm
shift      A/P  -2.0 mm  -2.66 mm
shift      L/R   4.0 mm   3.65 mm
The measured pose is assessed on the navigator itself: the head moved by the measured pose, navigated again, is compared with the navigator after the motion. Without correction, the difference is that of the motion; with the measured pose, what remains is the error of the pose.
realigned = navigator(move(measured_rotvec, measured_translation))


def nrmse(estimate, target):
    return float((estimate - target).norm() / target.norm())


for plane, before, after, target in zip(
    ("axial", "coronal", "sagittal"), reference, realigned, moved, strict=True
):
    print(
        f"{plane:>8}: NRMSE against the moved navigator, reference {nrmse(before, target):.3f}, "
        f"measured pose {nrmse(after, target):.3f}"
    )
   axial: NRMSE against the moved navigator, reference 0.335, measured pose 0.051
 coronal: NRMSE against the moved navigator, reference 0.332, measured pose 0.048
sagittal: NRMSE against the moved navigator, reference 0.421, measured pose 0.066
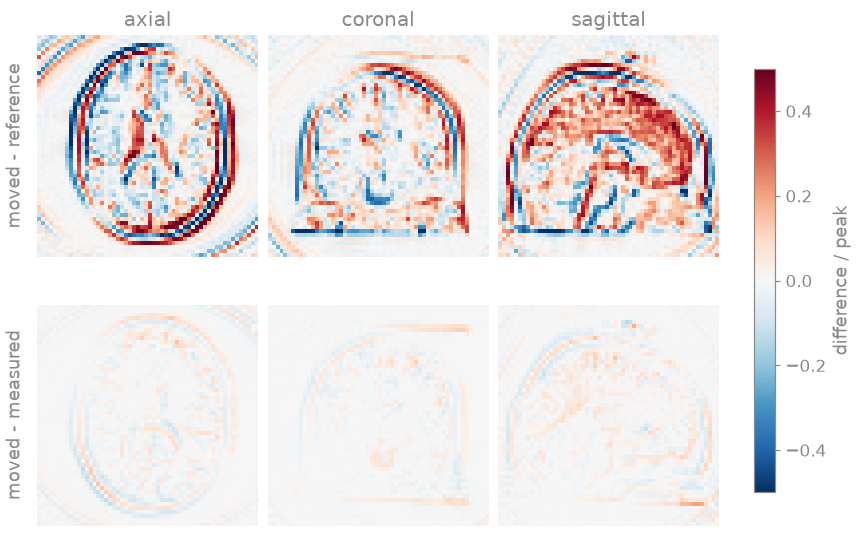
The residual error of the pose, a fraction of a degree and of a millimetre, has two sources: the navigator’s 4 mm resolution, and the through-plane motion, which each plane sees as a change of the anatomy in it rather than as a rigid motion within it. It is a small fraction of the 4 mm navigator voxel, and the residual difference is confined to the edges of the head.
A scan#
The head nods, a rotation about the left-right axis, by up to 2.3° with a
period of 8 s, and drifts by 3 mm along the superior-inferior axis over
12 s, with a navigator every 0.5 s. Each
navigator carries complex Gaussian k-space noise, so each measured pose
carries registration error. The filter’s process_noise is the variance
of the acceleration it allows between navigators, per pose coordinate, in
rad²/s⁴ and mm²/s⁴; measurement_noise is the variance it assigns to each
measured coordinate. The trace is filtered with three values of
process_noise; the largest leaves the filter at the measurements.
DT, COUNT = 0.5, 24
seconds = DT * np.arange(1, COUNT + 1)
nod = 0.04 * np.sin(2 * np.pi * seconds / 8)  # rad, about L/R
drift = 3.0 * seconds / seconds[-1]  # mm, along S/I
truth = np.zeros((COUNT, 6))
truth[:, 2], truth[:, 3] = nod, drift

generator = torch.Generator().manual_seed(0)
scan = [
    navigator(move((0.0, 0.0, a), (d, 0.0, 0.0)), noise=0.5, generator=generator)
    for a, d in zip(nod, drift, strict=True)
]


def track(process_noise):
    tracker = bt.NavigatorMotionTracker(process_noise=process_noise, measurement_noise=1e-4)
    tracker.track(reference, AXES, spacing=SPACING_MM)
    poses = [tracker.track(planes, AXES, dt=DT, spacing=SPACING_MM) for planes in scan]
    return np.array(
        [
            np.concatenate(
                [
                    Rotation.from_matrix(np.asarray(p.matrix)[:3, :3]).as_rotvec(),
                    np.asarray(p.translation),
                ]
            )
            for p in poses
        ]
    )


traces = {noise: track(noise) for noise in (1e2, 1e-3, 1e-4)}
rms = {noise: np.sqrt(np.mean((trace - truth) ** 2, axis=0)) for noise, trace in traces.items()}
for noise, error in rms.items():
    print(
        f"process_noise {noise:<6g} rms error: rotation "
        + ", ".join(f"{n} {np.degrees(e):.2f}°" for n, e in zip(NAMES, error[:3], strict=True))
        + "; shift "
        + ", ".join(f"{n} {e:.2f} mm" for n, e in zip(NAMES, error[3:], strict=True))
    )
process_noise 100    rms error: rotation S/I 0.48°, A/P 0.36°, L/R 0.40°; shift S/I 0.19 mm, A/P 0.42 mm, L/R 0.19 mm
process_noise 0.001  rms error: rotation S/I 0.42°, A/P 0.29°, L/R 0.36°; shift S/I 0.16 mm, A/P 0.41 mm, L/R 0.15 mm
process_noise 0.0001 rms error: rotation S/I 0.41°, A/P 0.24°, L/R 0.60°; shift S/I 0.15 mm, A/P 0.42 mm, L/R 0.13 mm
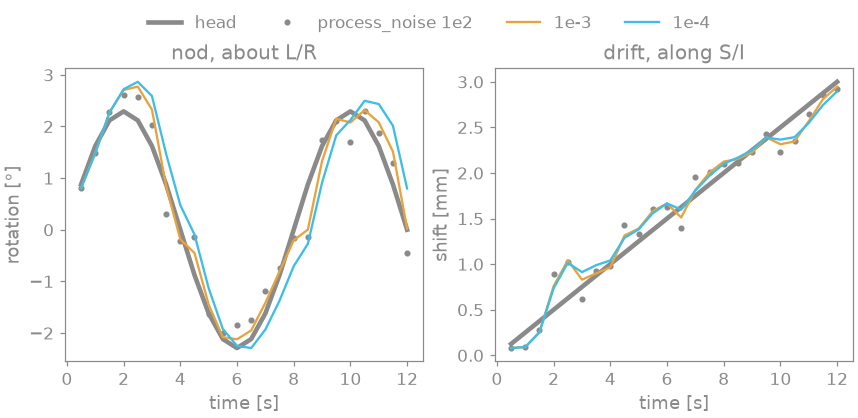
A large process_noise leaves the filter at the measurements; a small one
makes it trust its constant-velocity prediction, which smooths the
registration error and lags a change of direction: at 1e-4 the error of
the nod grows while that of the other coordinates falls. An error common to
every navigator, such as the offset of the A/P shift, is a bias of the
measurement and is not reduced by any value. The value that minimizes the
error depends on the motion and on the navigator’s precision, and is set
against a motion trace of the application.
References#
Total running time of the script: (0 minutes 4.614 seconds)