Learned regularization#
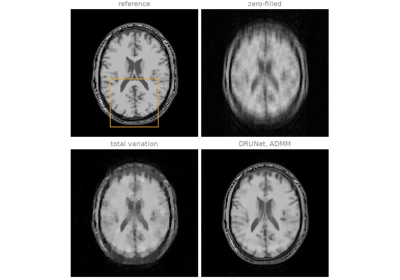
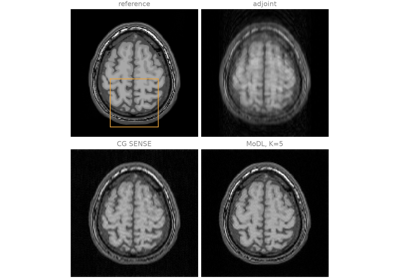
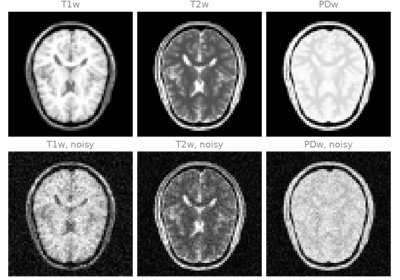
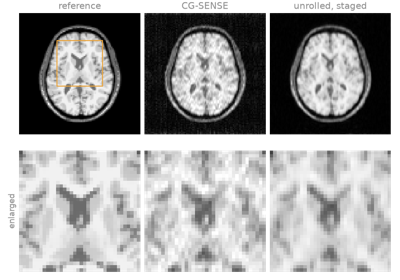
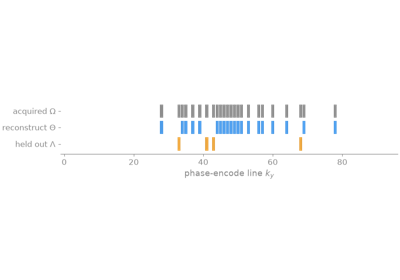
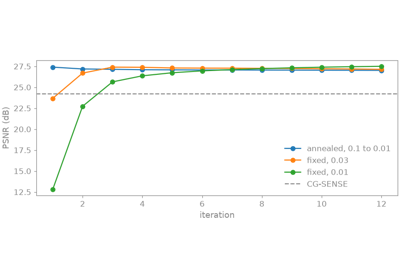
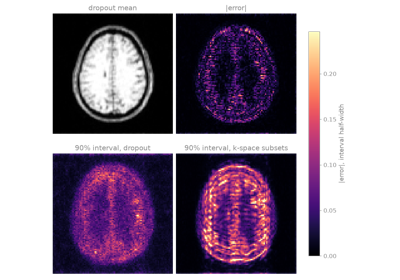
A learned reconstruction replaces the hand-specified regularization term by a neural network and keeps the encoding operator and the data consistency of the iterative reconstruction. This section starts with plug-and-play reconstruction, in which a pretrained denoiser takes the place of the proximal operator of ADMM and FISTA without any training, and proceeds to an unrolled network trained through BART’s ADMM (MoDL); networks for complex multi-contrast volumes, applied patch by patch; staged and self-supervised training of an unrolled network; plug-and-play with an annealed noise level; and calibrated voxel-wise uncertainty. Learned reconstruction describes where a network enters a reconstruction.
The section additionally requires:
pip install lightning torchio monai deepinv
The first lesson downloads the DRUNet weights deepinv distributes.